[email protected] • 678-564-6248 • linkedin.com/in/grant-gale-eng
I'm Grant Gale, a mechatronics engineer.
I am a student at Kennesaw State University with a passion for design, problem solving, and innovation.
Project Portfolio
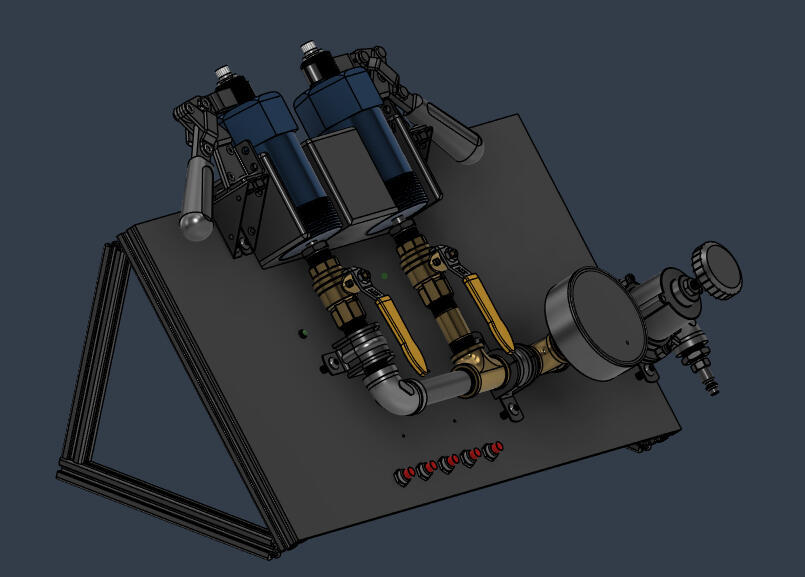
ELLD Test Fixture
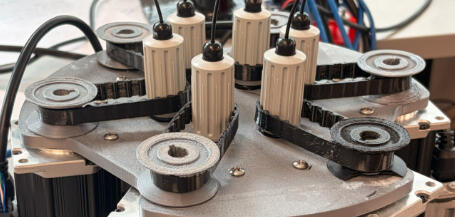
Catheter-Based Surgical Robot
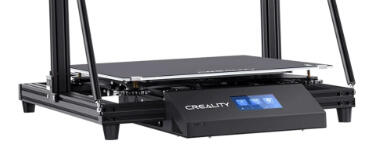
CR10-Max Rebuild
More About Me
I am a student at KSU pursuing a bachelors degree in Mechatronics Engineering and a masters in Intelligent Robotic Systems. I am most proficient in applications of electrical engineering. I also have experience with programming, CAD for engineering, and hardware design. I have a good blend of professional and research experience.
When I am not at work or school, I am usually training martial arts or exploring outside. On the weekends, I work for the university recreation department as an outdoor trip leader. I take students and alumni on outdoor adventures of all kinds. I am most often found leading backpacking, rock climbing, or caving trips.
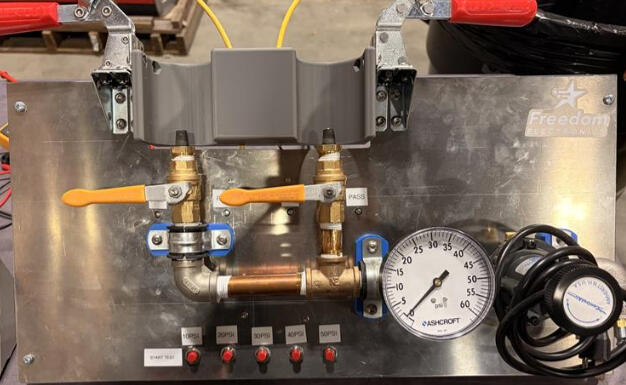
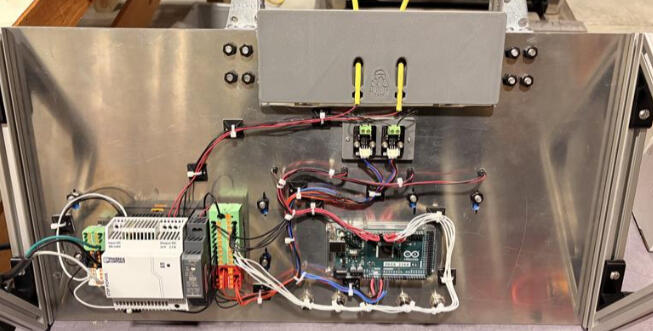
Test Fixture for Electronic Line Leak Detectors
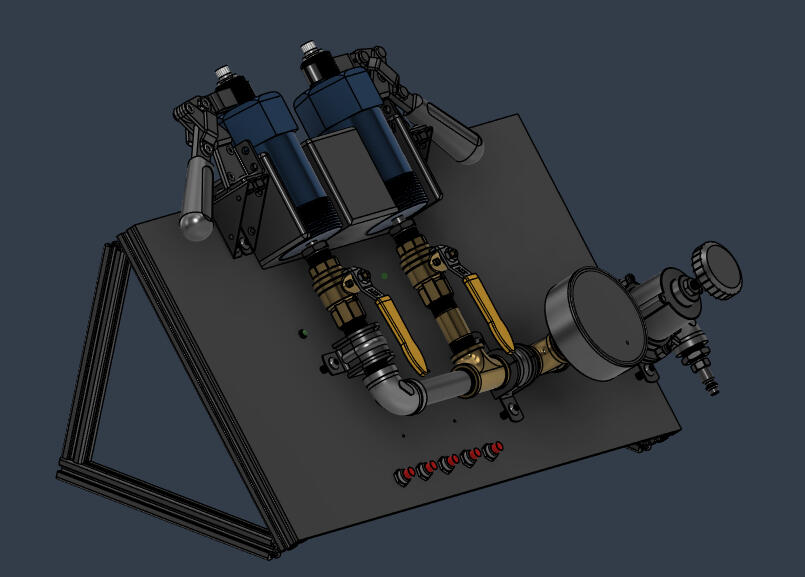
- Designed and developed an ELLD pressure test fixture to verify sensor output across multiple pressure ranges.- Created and revised fixture components using Fusion 360 and 3D-printed parts for proper fit and test setup.- Wired the fixture electronics, including Arduino control, buttons, LEDs, analog inputs, and pressure/current signal connections.- Programmed Arduino logic for pressure selection, signal reading, pass/fail output, and serial monitor feedback.- Worked through multiple design and code revisions to improve fixture reliability and usability.- Troubleshot wiring, sensor readings, calibration issues, voltage/current conversion, and inconsistent test results.- Helped document the fixture setup and test process for future engineering and manufacturing use.
Catheter-Based Robot
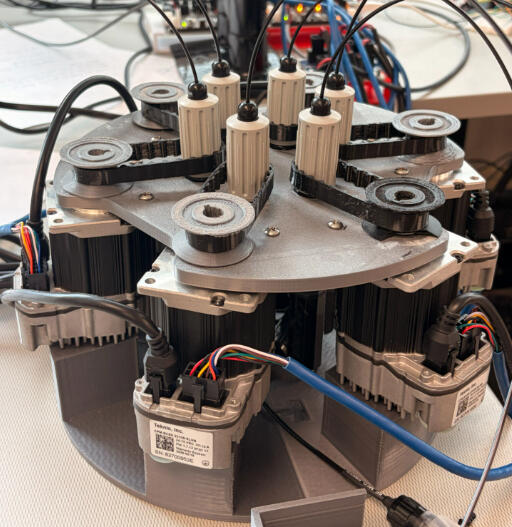
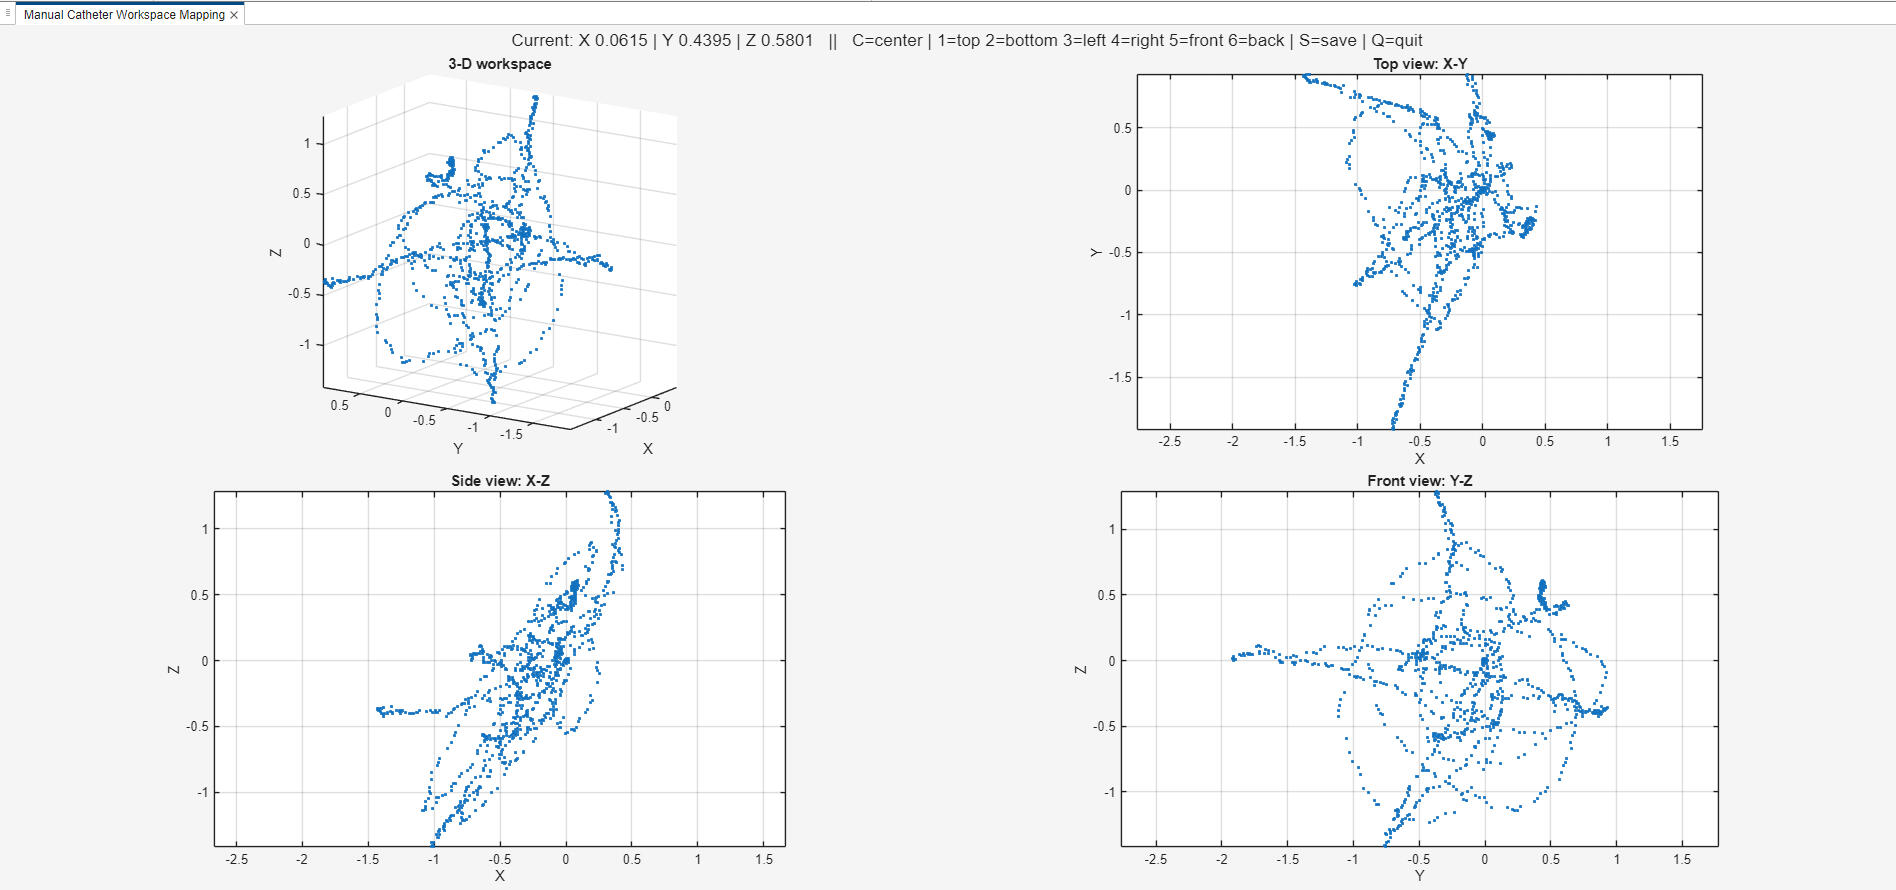
- Used MATLAB to integrate motor control and sensor inputs into one coherent system.- Worked with teammates to design and fabricate multiple iterations of the device.- Tested different materials and mechanical revisions to improve movement.- Created 3D range-mapping to evaluate the robot’s range of motion and convert raw motor control to consistent and predictable movement patterns
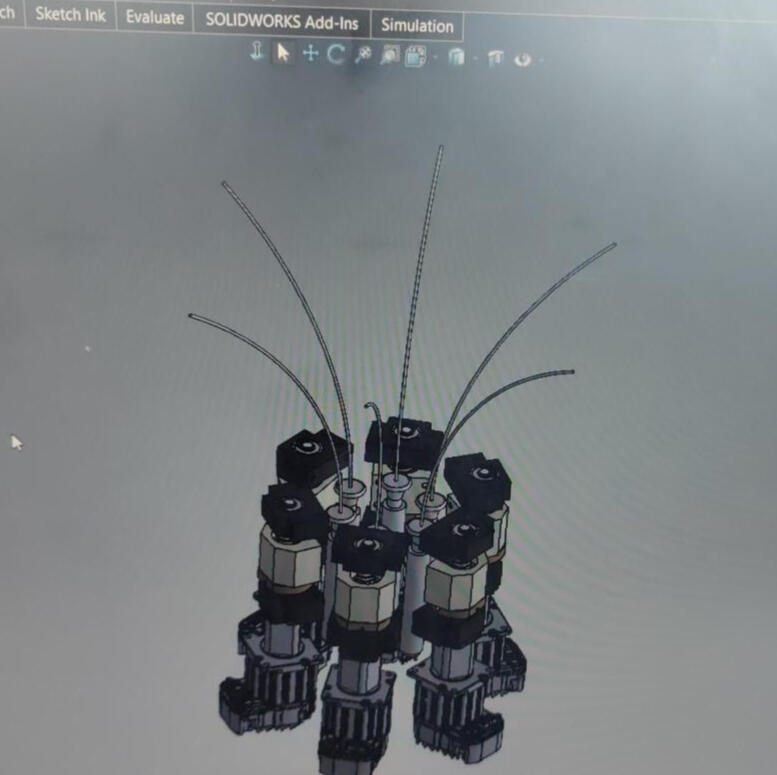
3D Instrument range mapping using MATLAB
Creality CR10-Max Conversion
I was tasked with repurposing our old large print volume machine to give it new life. With 50 dollars and some rewiring, I saved my company thousands of dollars.
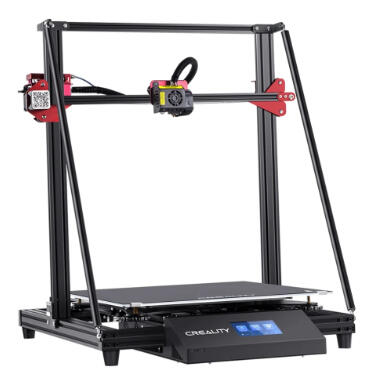
Because many of our in house fixtures use housing that was designed with a large format 3D printer in mind, we either had to get this machine running again or buy a new one. Unfortunately this specific model has been discontinued, and a new printer with the same bed size would cost thousands of dollars.
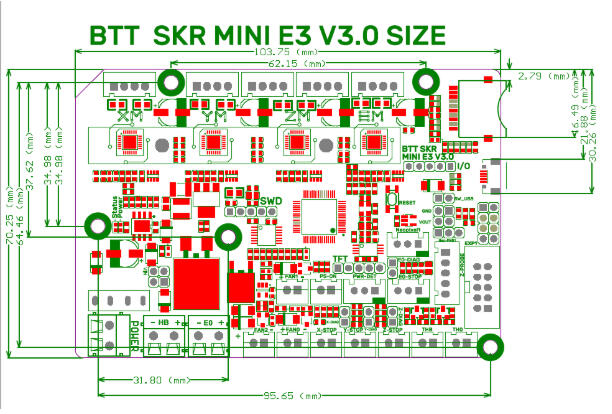
Using the old frame and hardware, I did a full motherboard swap and converted the outdated machine to run on open source parts and firmware. Not only does this get the printer running again for a fraction of the cost, it also ensures the printer can be repaired in the future.